RoboBricks
Using material data to drive robotic disassembly and reassembly.
A robotic fabrication workflow that uses computer vision to evaluate reclaimed blocks and translate their material characteristics into a data-driven assembly.
How can the imperfections of existing building materials become inputs for new architectural assemblies?
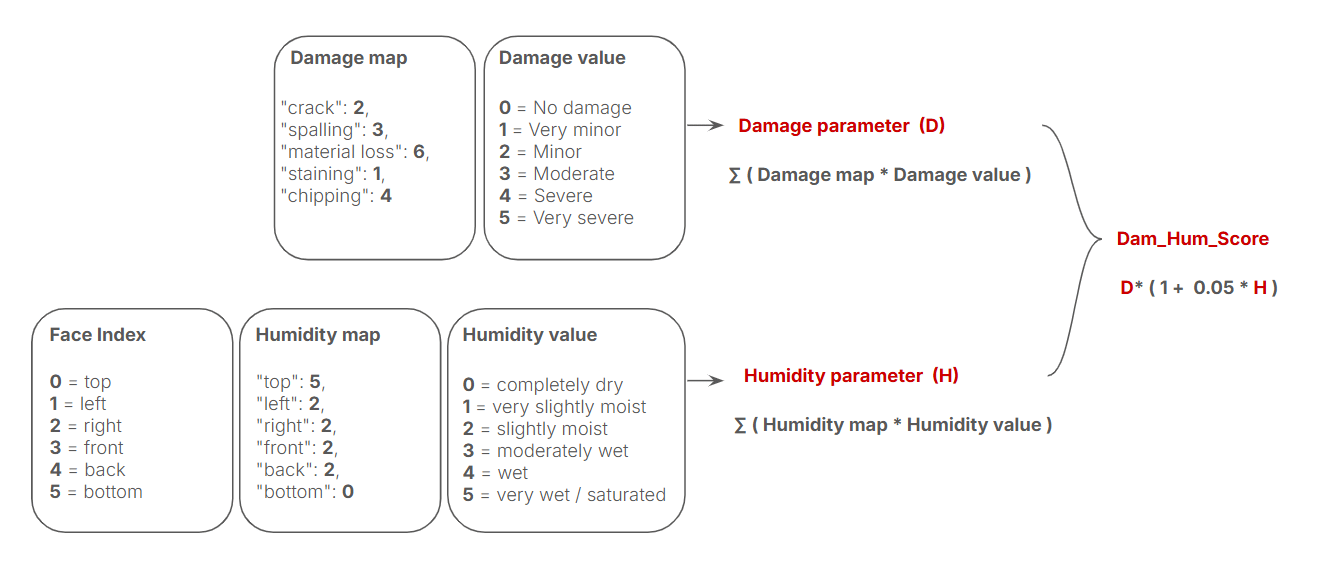
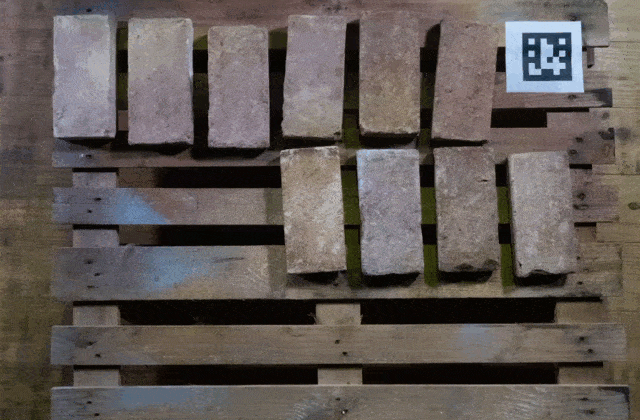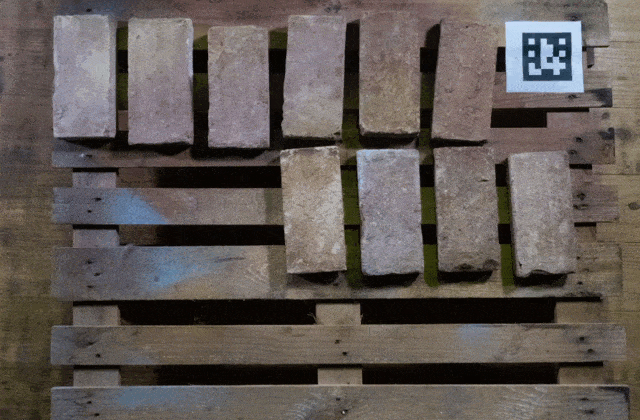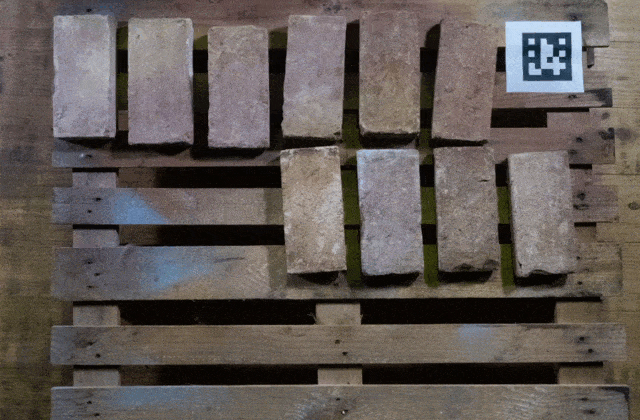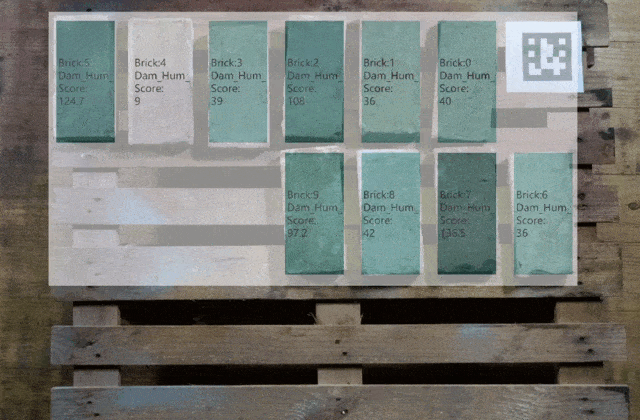
This project explored a robotic workflow for disassembling, evaluating and reassembling construction blocks. A robotic arm moved individual blocks through an imaging station, where computer vision was used to evaluate surface characteristics associated with moisture. The resulting data was structured into a graded material dataset and used to control the distribution of blocks within a new parametric assembly.
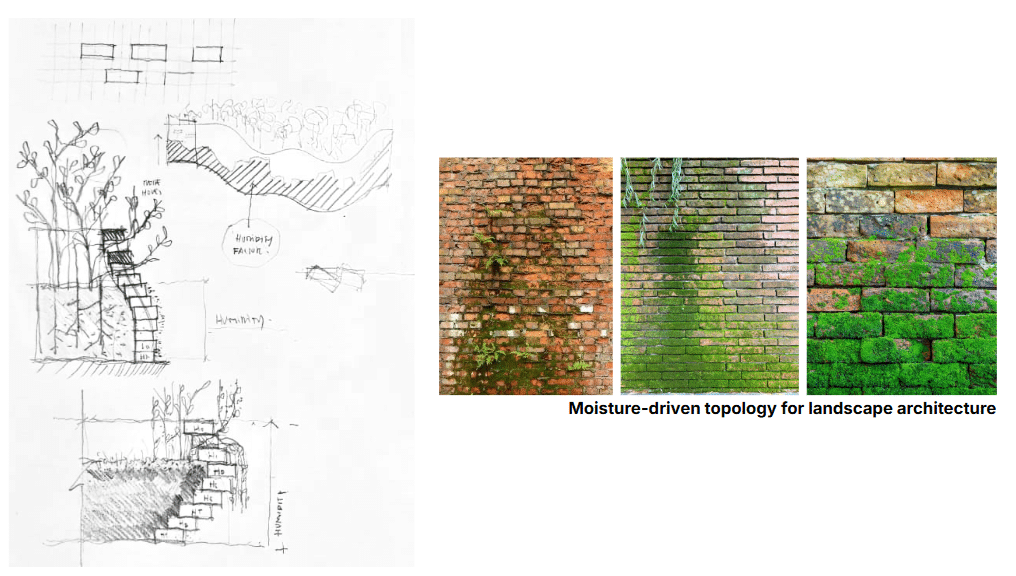
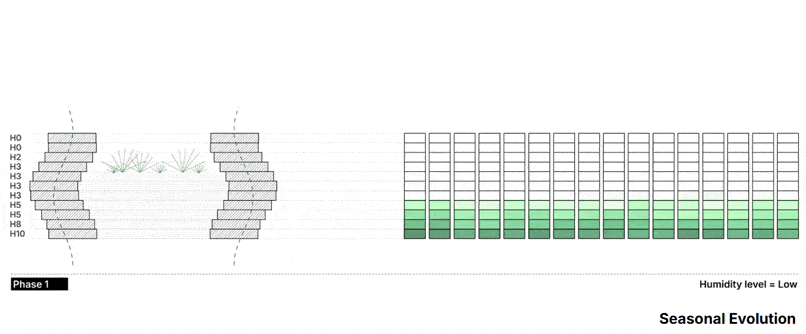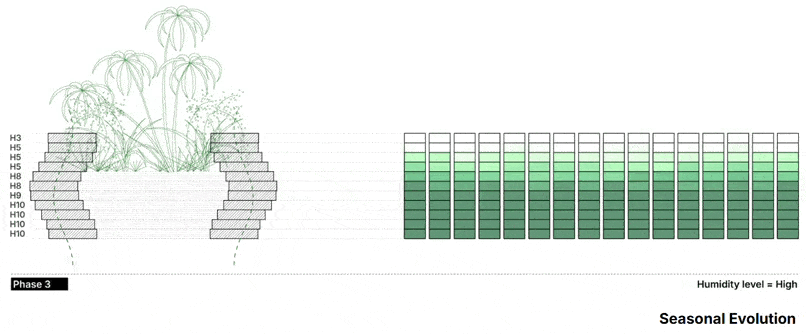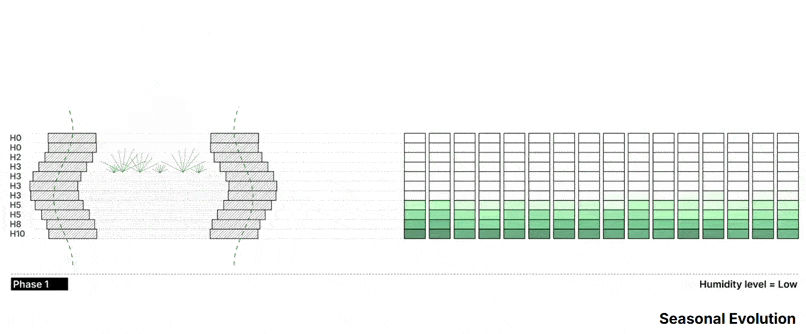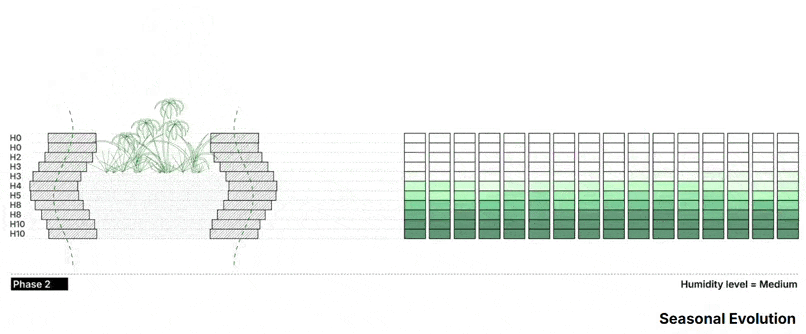
Rather than treating moisture and weathering as defects, the system uses them as design parameters, positioning more bioreceptive blocks to support moss and vegetation and allowing the resulting façade to evolve over time.
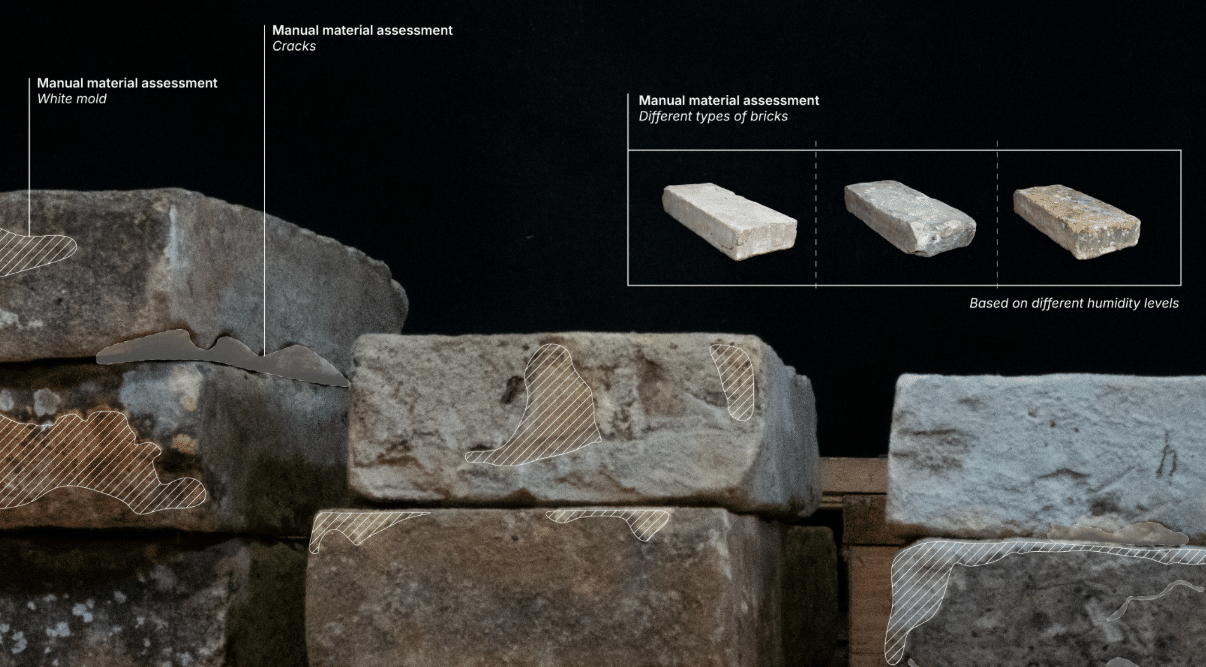
Recover and organise existing blocks using robotic pick-and-place operations.
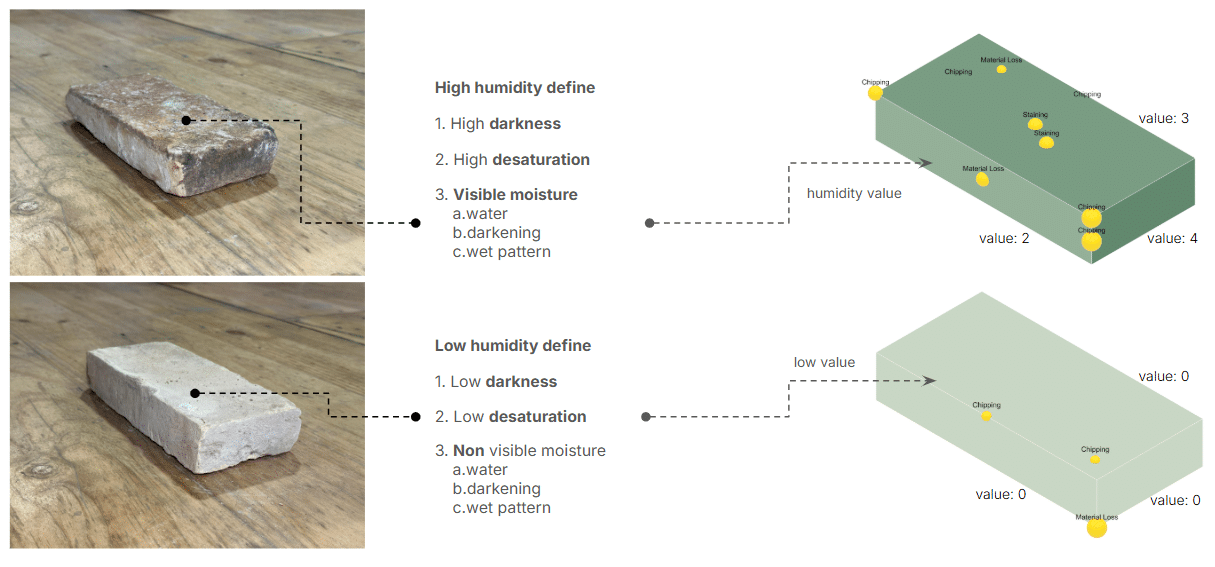
Capture multiple faces of each block and evaluate visible surface characteristics.
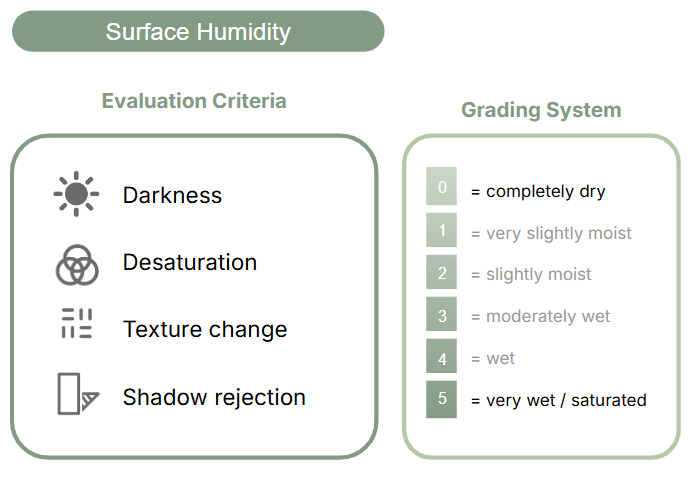
Convert darkness, desaturation, texture change and shadow rejection into a structured 0–5 moisture score.
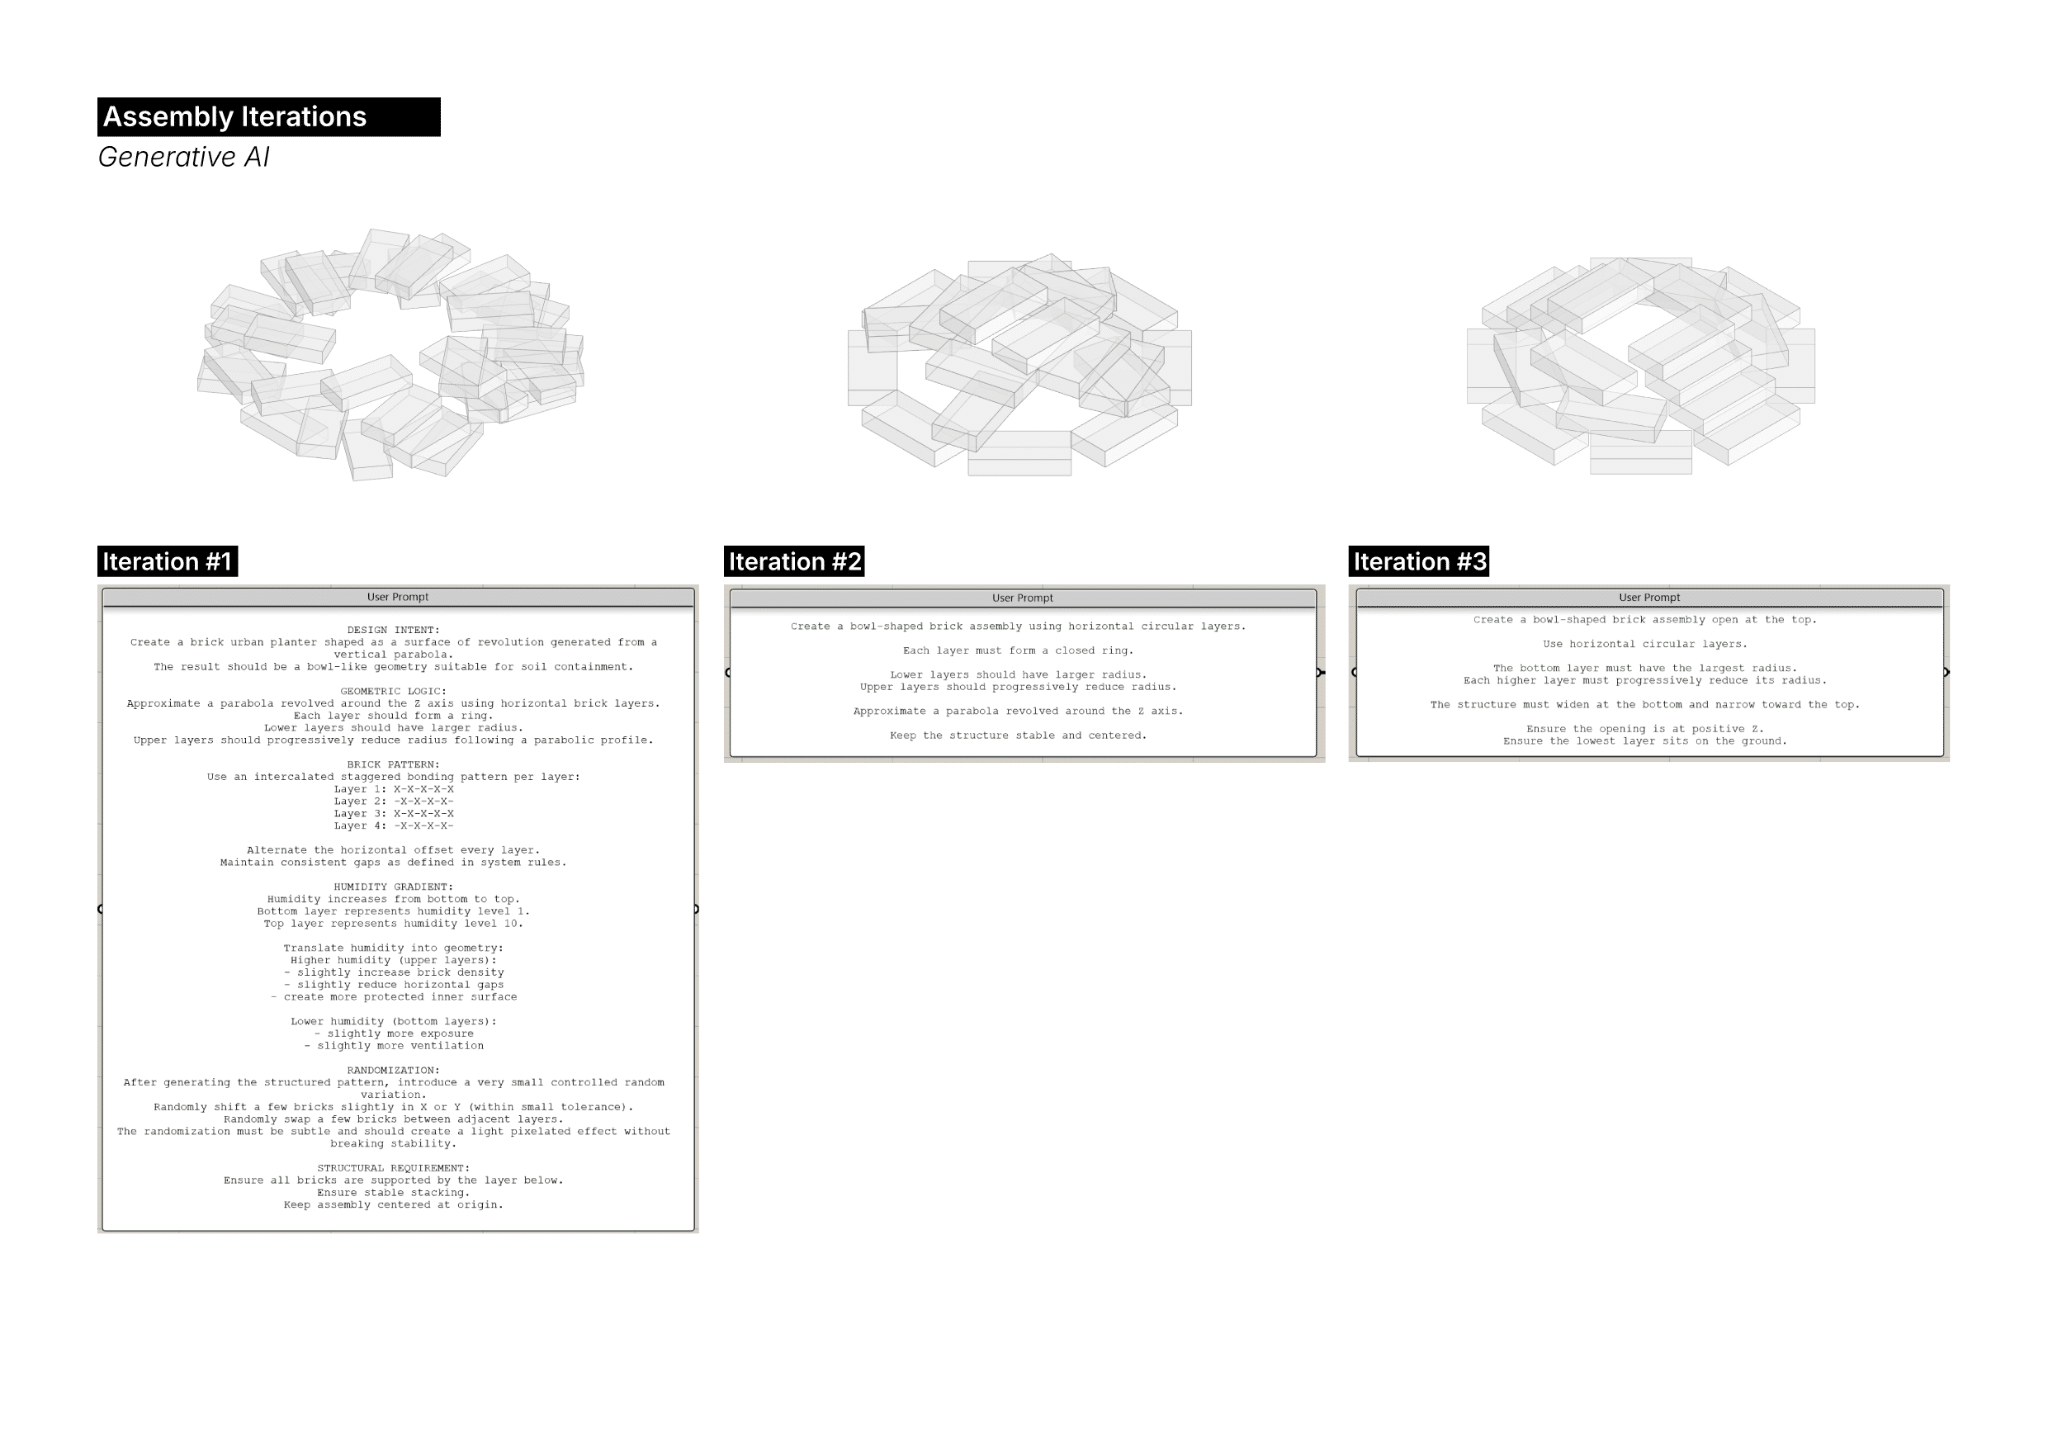
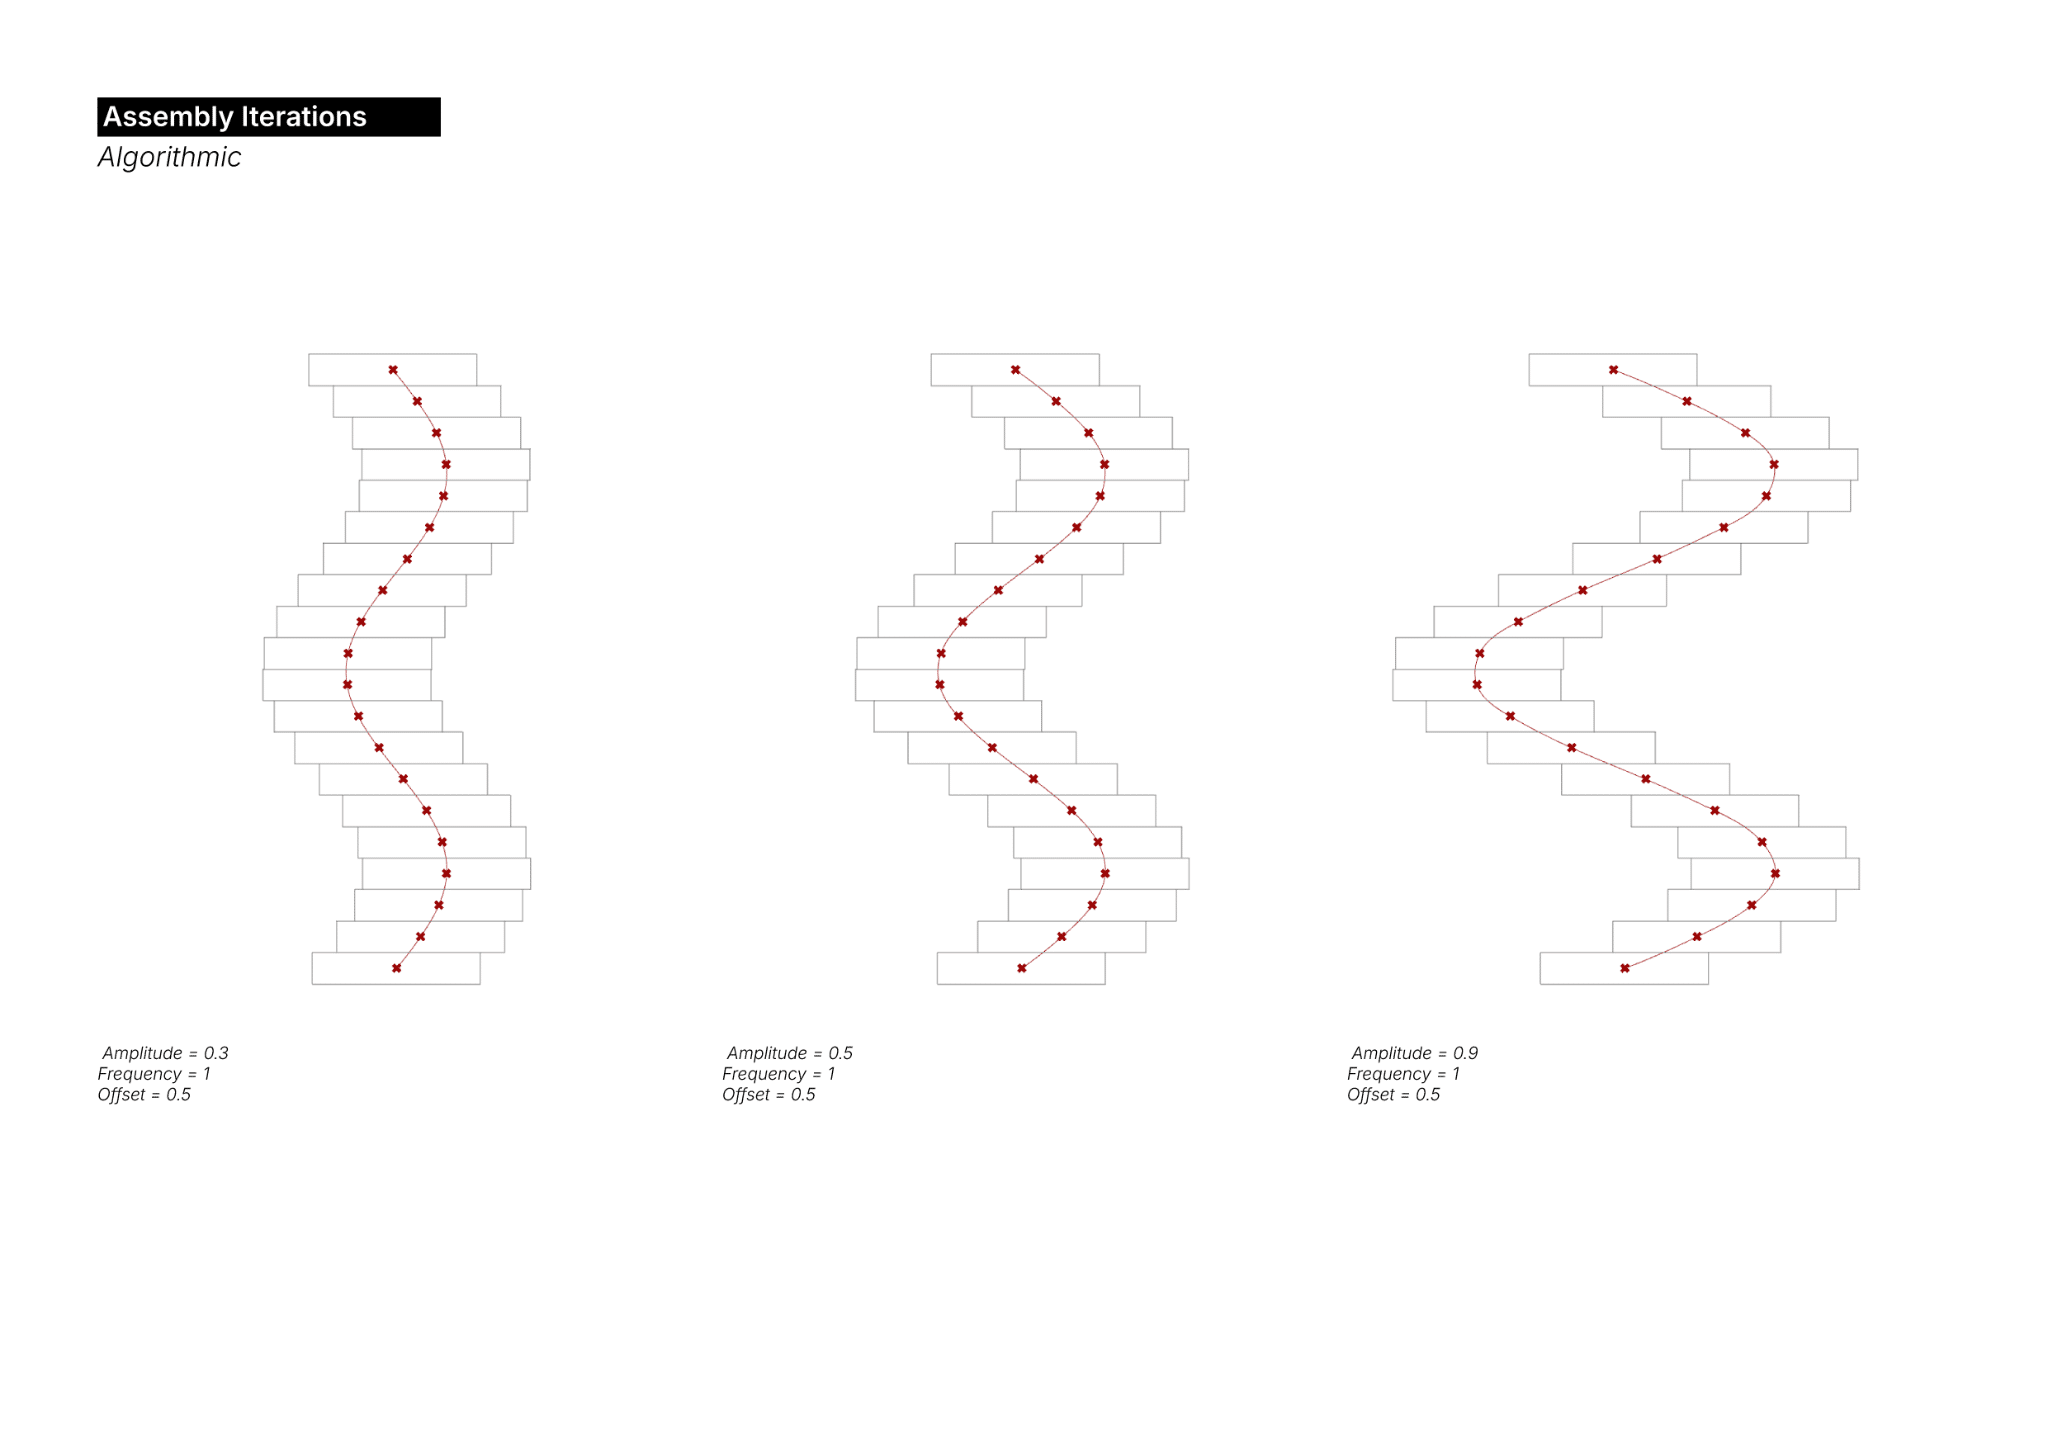
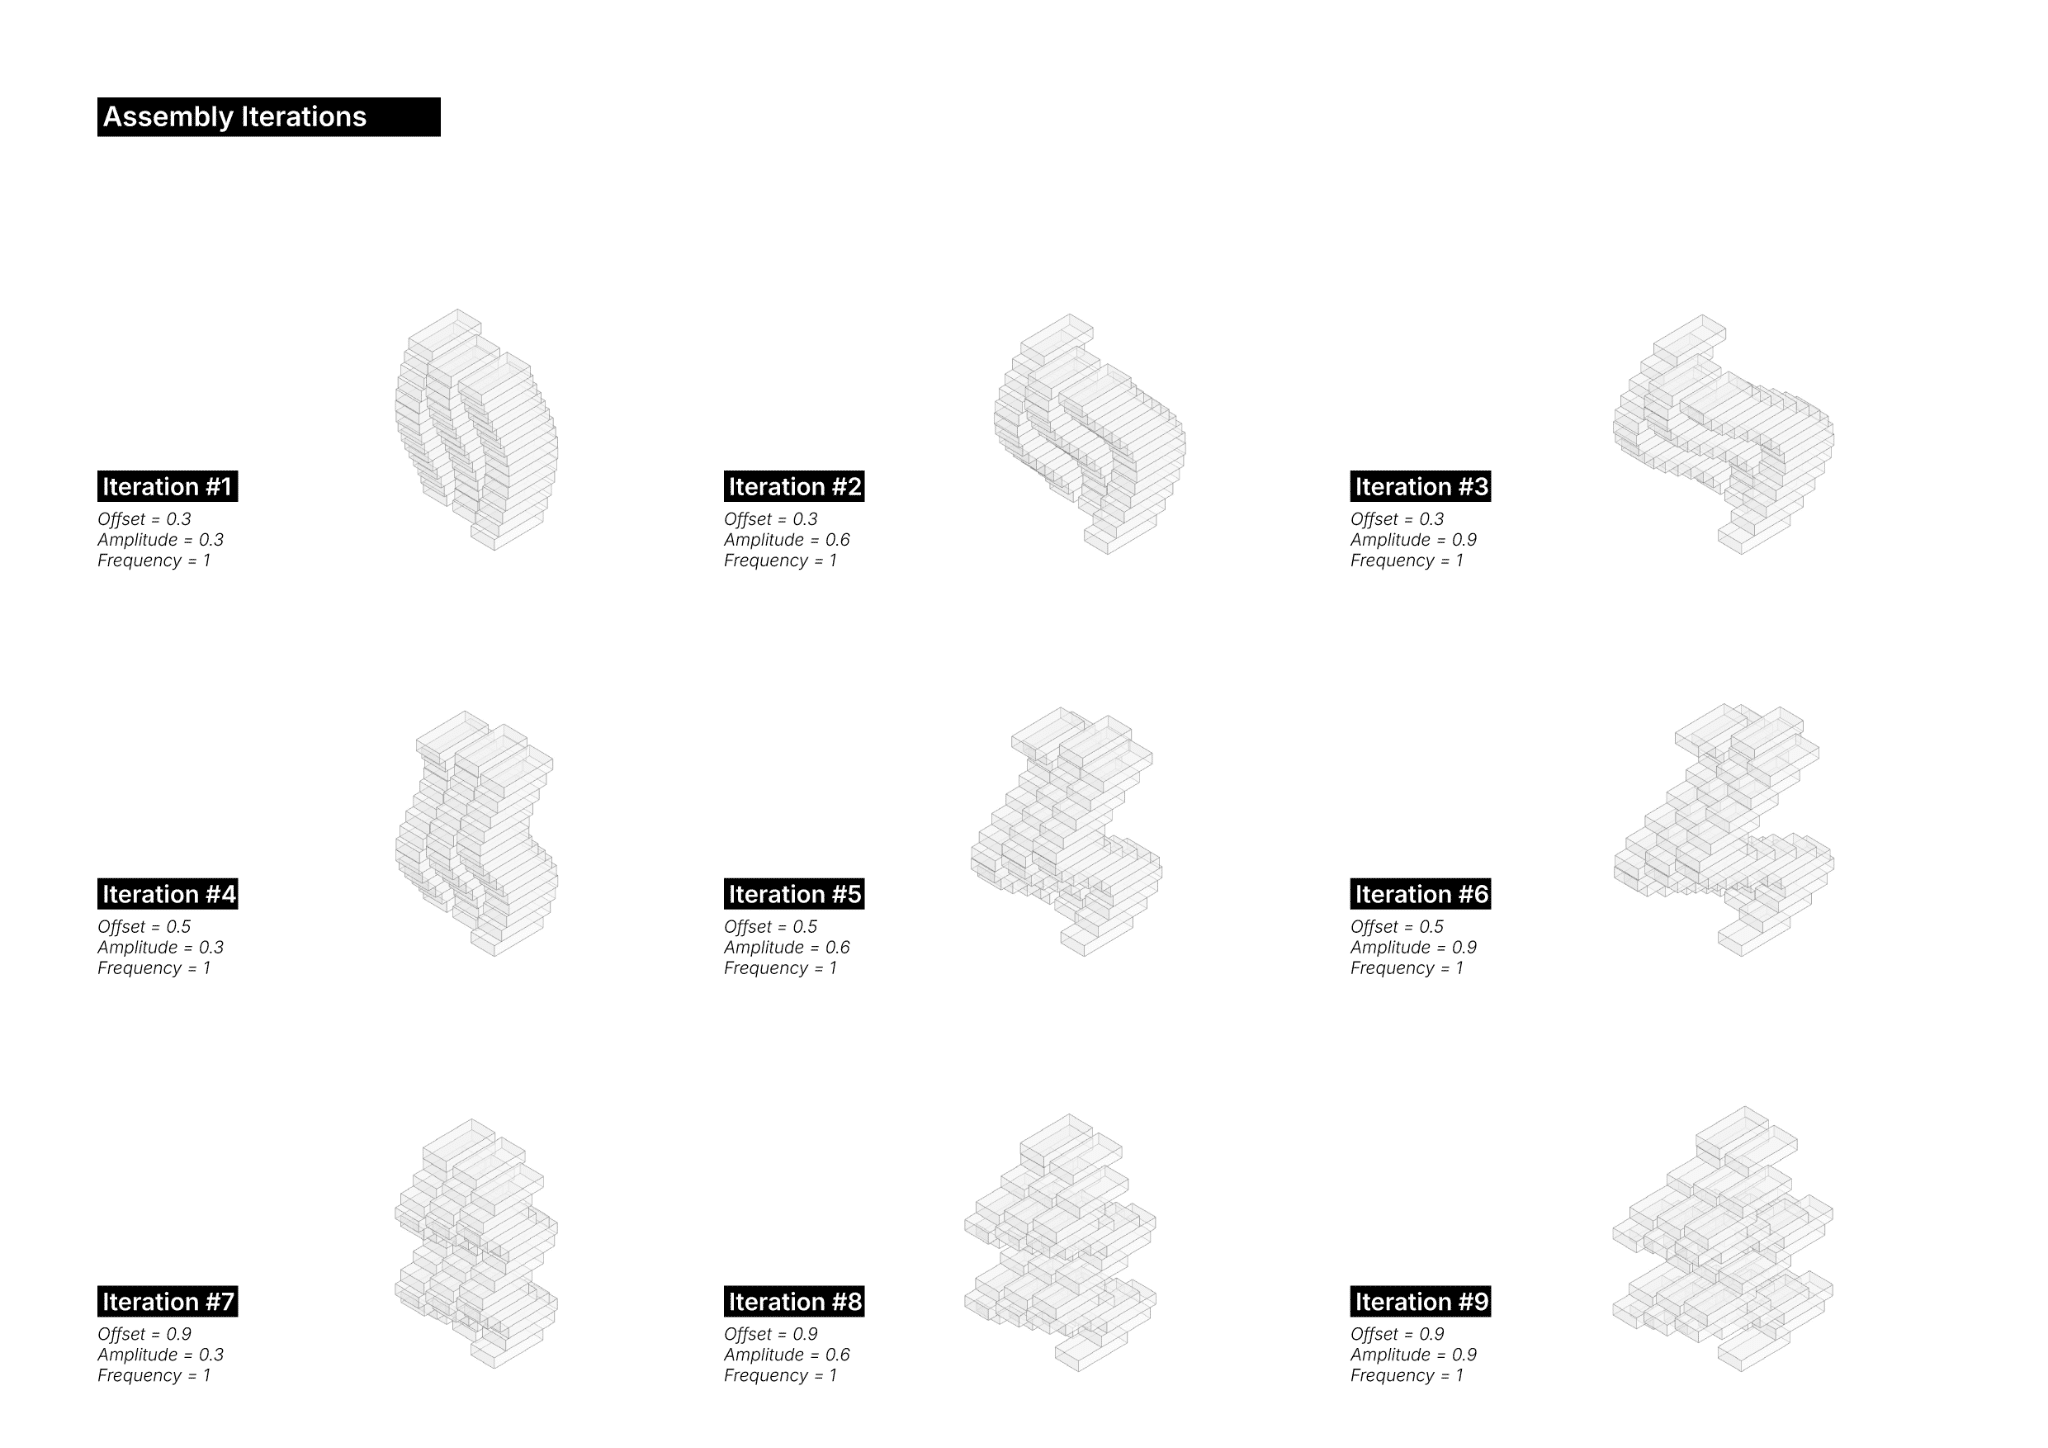
Use the material dataset to control block position and orientation within a parametric assembly.
Send the selected configuration back to the robotic system for physical fabrication.